Self-balancing robot
- Parts
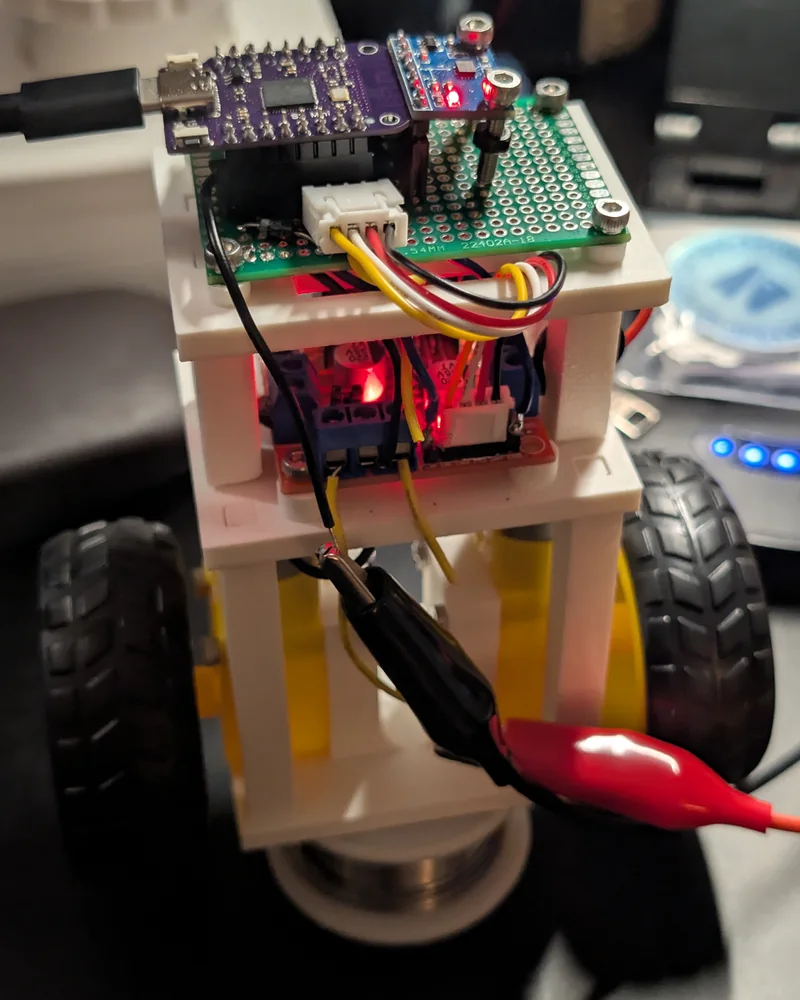
- ESP32-S2, ICM42688 IMU over SPI, L298N motor driver (HW-095 board), 3D-printed chassis
- How it estimates tilt
- A complementary filter blends the gyro and accelerometer (alpha 0.98). Control runs at about 100 Hz, and the motors cut off past 35° of tilt.
- Works now
- Sensor reads and the control loop
- Not yet
- PID tuning
- Next step
- Log the tilt estimate (accelerometer only, gyro only, blended) while tilting it by hand, and post the plot.